> ## Documentation Index
> Fetch the complete documentation index at: https://docs.cyberwave.com/llms.txt
> Use this file to discover all available pages before exploring further.
# Cyberwave documentation
> Guides, tutorials and reference for connecting AI to robots with Cyberwave.
## Try it now
**2 min · browser only.** Control a real SO-101 in our Milan lab from your browser.
**5 min · no code.** Add a twin, press Simulate, drive it with your keyboard.
**20 min · Python + webcam.** A camera spots a cup; the arm picks it and sorts it, in the free Playground sim.
## The platform at a glance
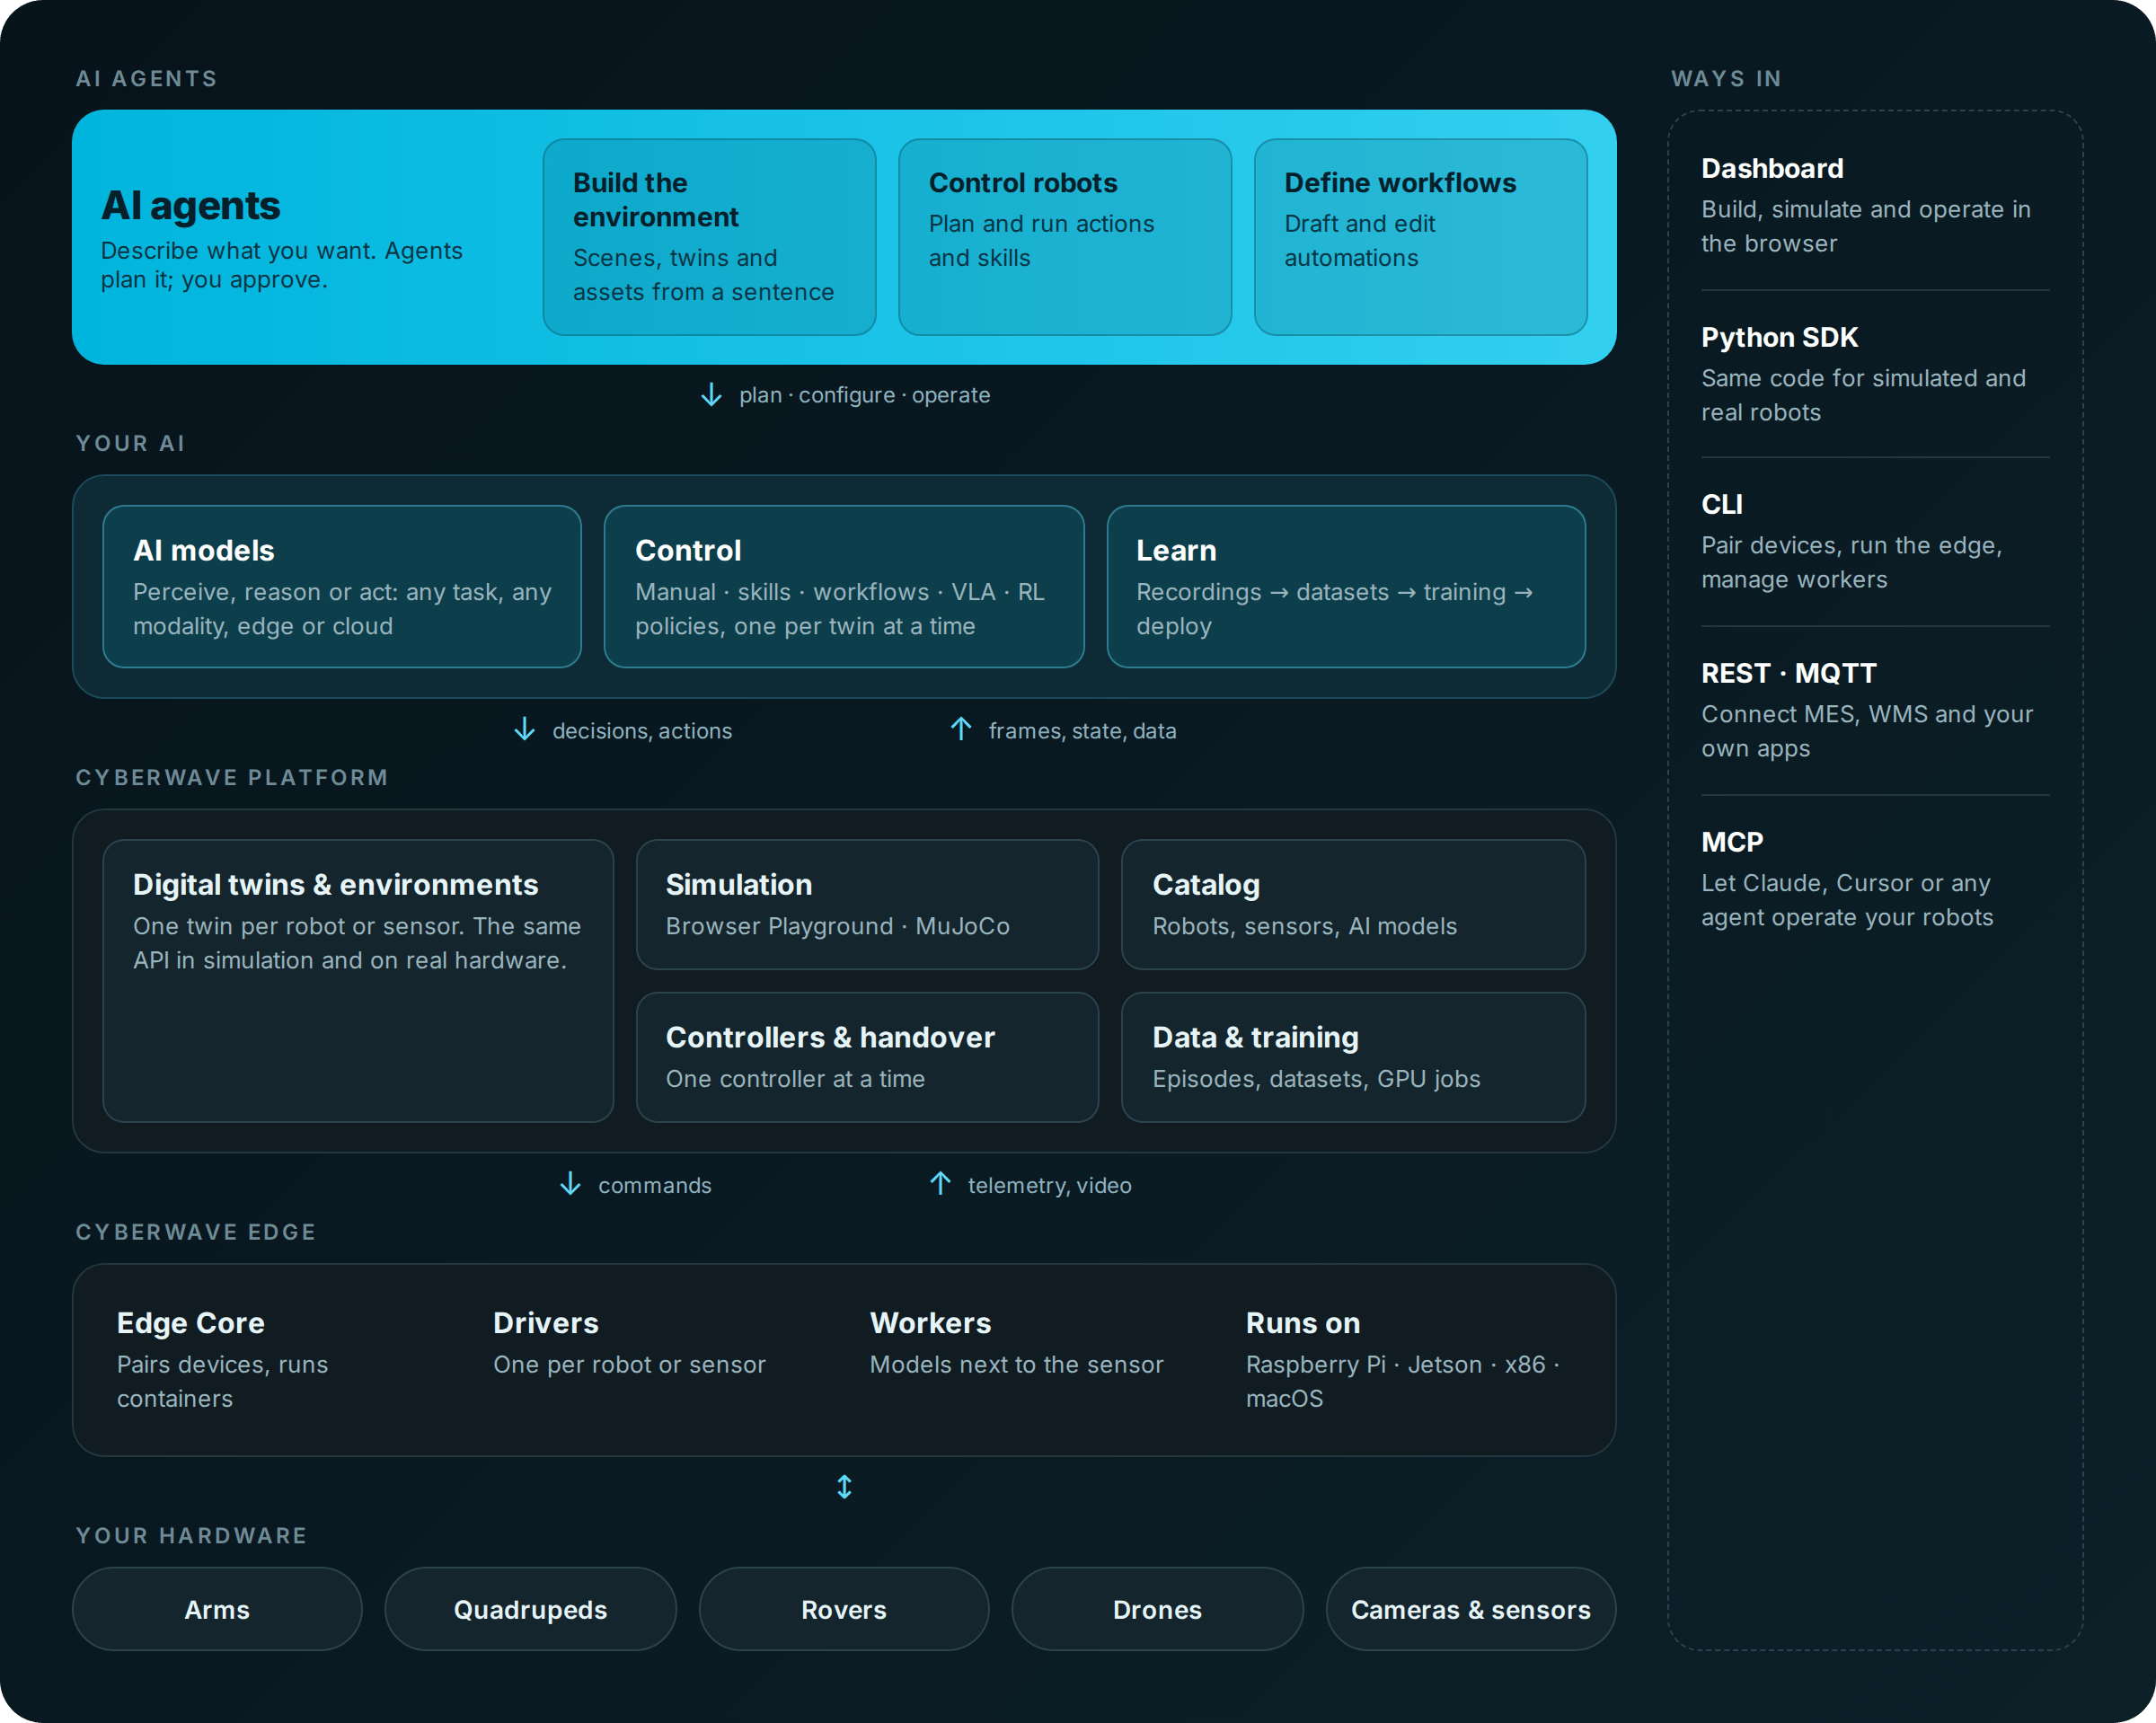
**AI agents on top, your robots at the bottom, Cyberwave in between.** Agents plan and configure; perception models, controllers and learned policies act through digital twins. Cyberwave Edge connects the twins to real hardware. You get in through the dashboard, the Python SDK, the CLI, REST and MQTT, or MCP.
## How AI reaches a robot
Describe what you want. Agents build the environment, control the robot and write workflows, and you approve every plan.
Models that perceive (detection, depth, speech), reason (VLMs, LLMs) or act (VLA, RL), on the edge or in the cloud.
Five ways to drive your robots: manual input, skills, workflows, VLA models and RL policies. Switch any time.
Every run becomes data. Datasets train the next model, which deploys back to the same twin.
[How it all fits together →](/ai/overview)
## What it looks like in code
```python theme={null}
# pip install cyberwave · export CYBERWAVE_API_KEY=...
import time
from cyberwave import Cyberwave
cw = Cyberwave()
arm = cw.twin("the-robot-studio/so101") # creates or reuses "Quickstart Environment"
cw.affect("playground") # free browser simulation; "live" for the real robot
arm.policy.ensure_attached() # the SDK takes control of the twin
time.sleep(2)
arm.joints.set("shoulder_pan", 45, degrees=True)
print(arm.joints.get())
```
```python theme={null}
# pip install "cyberwave[ml]" opencv-python
import cv2
from cyberwave import Cyberwave
cw = Cyberwave()
model = cw.models.load("yolo26n.pt") # from the catalog, runs locally
ok, frame = cv2.VideoCapture(0).read() # your laptop webcam
result = model.predict(frame, confidence=0.5)
print(result.describe()) # detections with labels and scores
# Next: pick and sort what the camera sees -> /overview/first-ai-loop
```
```python theme={null}
from cyberwave import Cyberwave
cw = Cyberwave()
go2 = cw.twin("unitree/go2")
env = go2.environment_id
plan = cw.agents.control.plan(env, "Move the Go2 to waypoint A", twin_uuid=go2.uuid, mode="simulation")
actions = plan.get("dispatchable_actions") or []
if not actions:
raise SystemExit(f"Nothing to dispatch: {plan}")
print(actions[0]) # review before you confirm
action = cw.control.dispatch(env, actions[0], confirmed=True, mode="simulation")
cw.actions.wait(action["action_id"], twin_uuid=go2.uuid, timeout=60)
```
The environment needs a waypoint named "A". More in [Control agent](/ai/control-agent).
Get an API key under [API tokens](/feature-reference/api-tokens). `cw.affect("simulation")` starts a MuJoCo instance, which uses [credits](/billing/credits); `"playground"` is free. Stuck? See [troubleshooting](/support/troubleshooting).
## Works across form factors
Arms, quadrupeds, rovers, drones and cameras all become digital twins with the same API. What a twin can do (move joints, grip, drive, fly, stream video) comes from its capabilities, not its brand. [How hardware works →](/robots/overview)
SO-101, UR, Piper, OpenArm…Go2, Spot, UGV Beast…DJI Mini, PX4 Vision…USB, RTSP, GigE, RealSense…
Is your device supported? Check the [compatibility table](/overview/supported-hardware), or [add your robot](/robots/add-your-robot).
## Choose your path
Python SDK, CLI, MCP.Record, train a VLA or RL policy, and deploy it.Workflows, from simulation to fleet.Get your hardware listed and supported.Deployment, security, fleet ops.Troubleshooting, Discord, status.
## See it in 60 seconds
This documentation is built and hosted on [Mintlify](https://mintlify.com), a developer documentation platform.
 ## Try it now
 ## How AI reaches a robot